中国科学院大学学报 ›› 2026, Vol. 43 ›› Issue (6): 834-846.DOI: 10.7523/j.ucas.2024.066
杨秋宇1, 缐凯2, 郭继孚2, 朱重远2, 焦建彬3( )
收稿日期:2024-01-29
修回日期:2024-06-25
发布日期:2024-07-17
通讯作者:
焦建彬
基金资助:
Qiuyu YANG1, Kai XIAN2, Jifu GUO2, Zhongyuan ZHU2, Jianbin JIAO3()
Received:2024-01-29
Revised:2024-06-25
Published:2024-07-17
Contact:
Jianbin JIAO
摘要:
精准感知周围车辆的未来行动对自动驾驶的安全性保障有着至关重要的作用。已有的轨迹预测方法可以大致分为联合预测和边际预测2类,尽管联合预测方法在多车问题上能取得更好的场景一致性,但在长时间预测上这2类方法都存在局限,因为它们无法模拟驾驶员决策随时间的变化。针对此问题,提出全新的联合预测方法(TPP),其核心是轨迹后处理模块。该模块利用注意力机制构建不同车辆间的交互,通过单车多编码的设计模拟车辆行驶中决策的更新,最终利用解码器生成具有场景一致性的多车轨迹。分别在短时预测数据集和长时预测数据集上对该方法进行评估,并与主流的轨迹预测方法进行对比。结果表明,TPP方法取得了更好的性能表现。
中图分类号:
杨秋宇, 缐凯, 郭继孚, 朱重远, 焦建彬. 基于场景上下文信息的长时多车轨迹预测[J]. 中国科学院大学学报, 2026, 43(6): 834-846.
Qiuyu YANG, Kai XIAN, Jifu GUO, Zhongyuan ZHU, Jianbin JIAO. Long-term multi-vehicle trajectory prediction with scene contextual information[J]. Journal of University of Chinese Academy of Sciences, 2026, 43(6): 834-846.
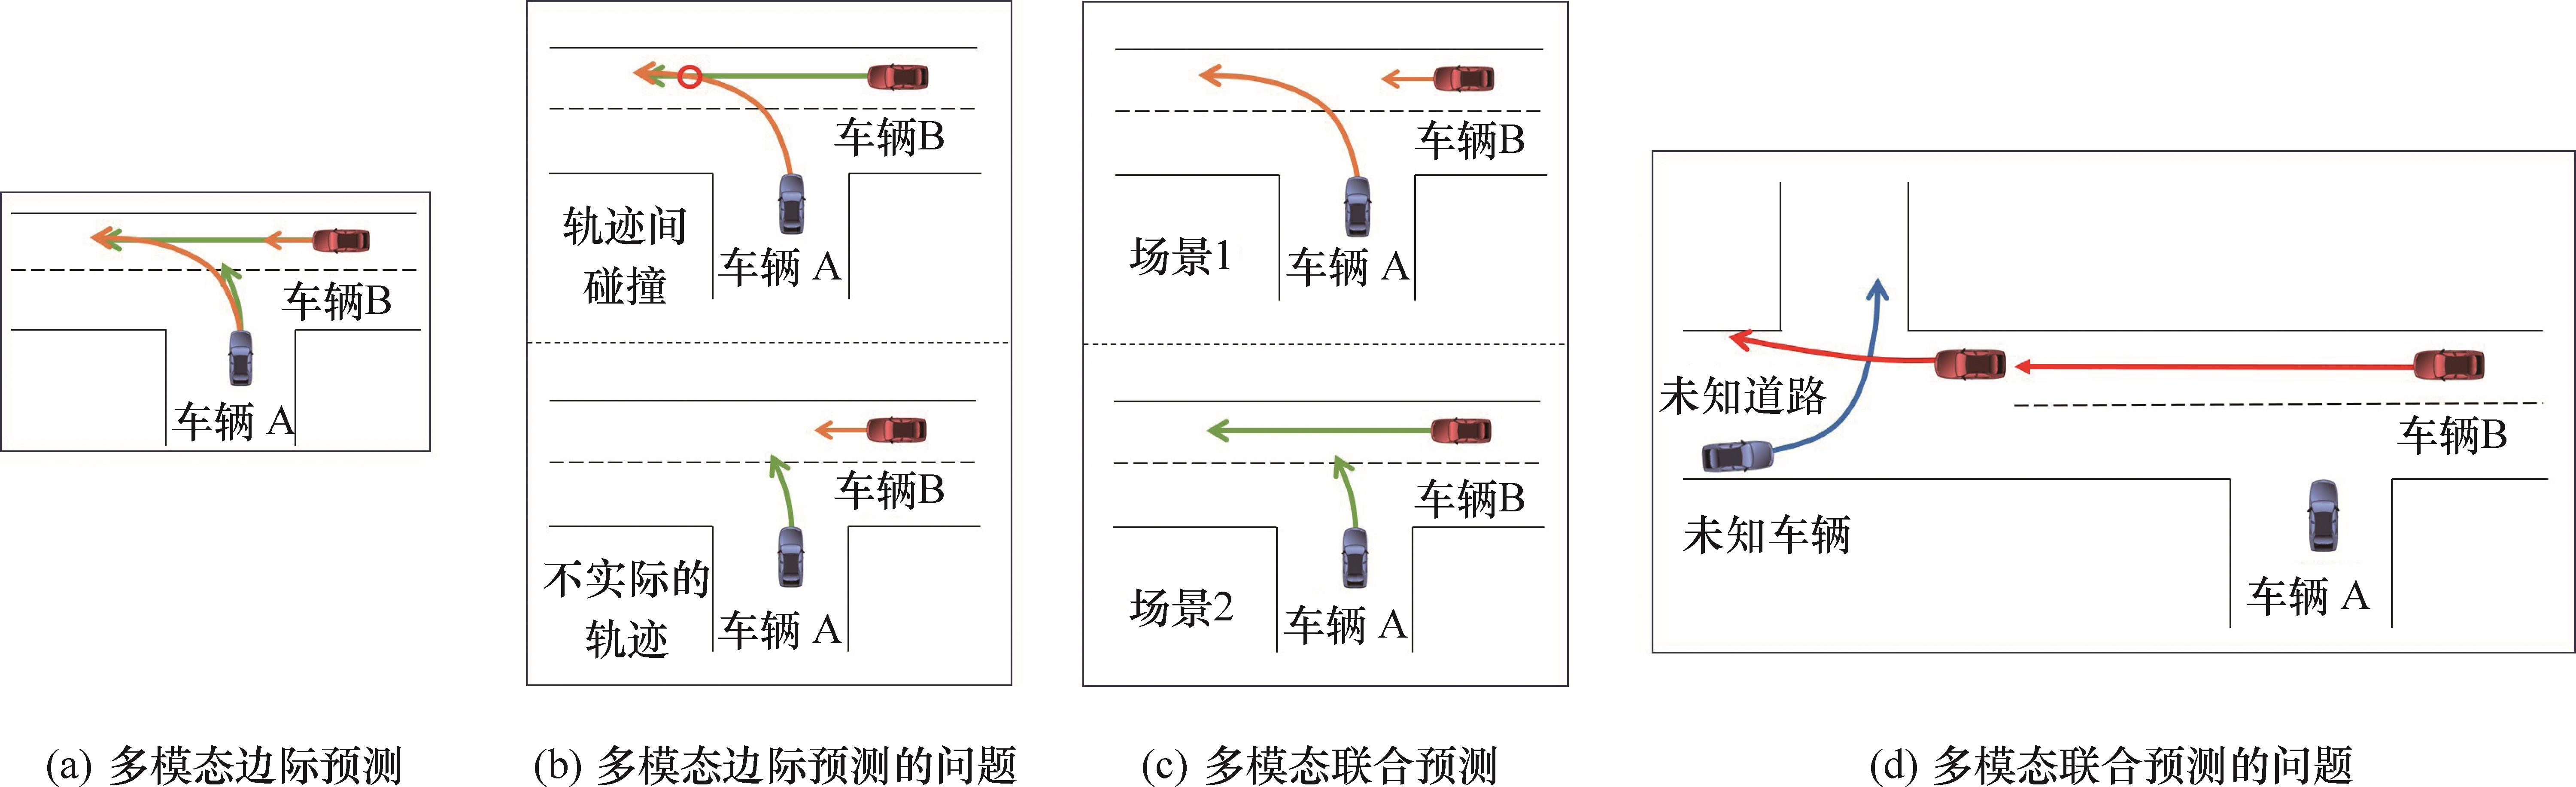
图1 轨迹预测任务示意图
Fig.1 Schematic of trajectory prediction task
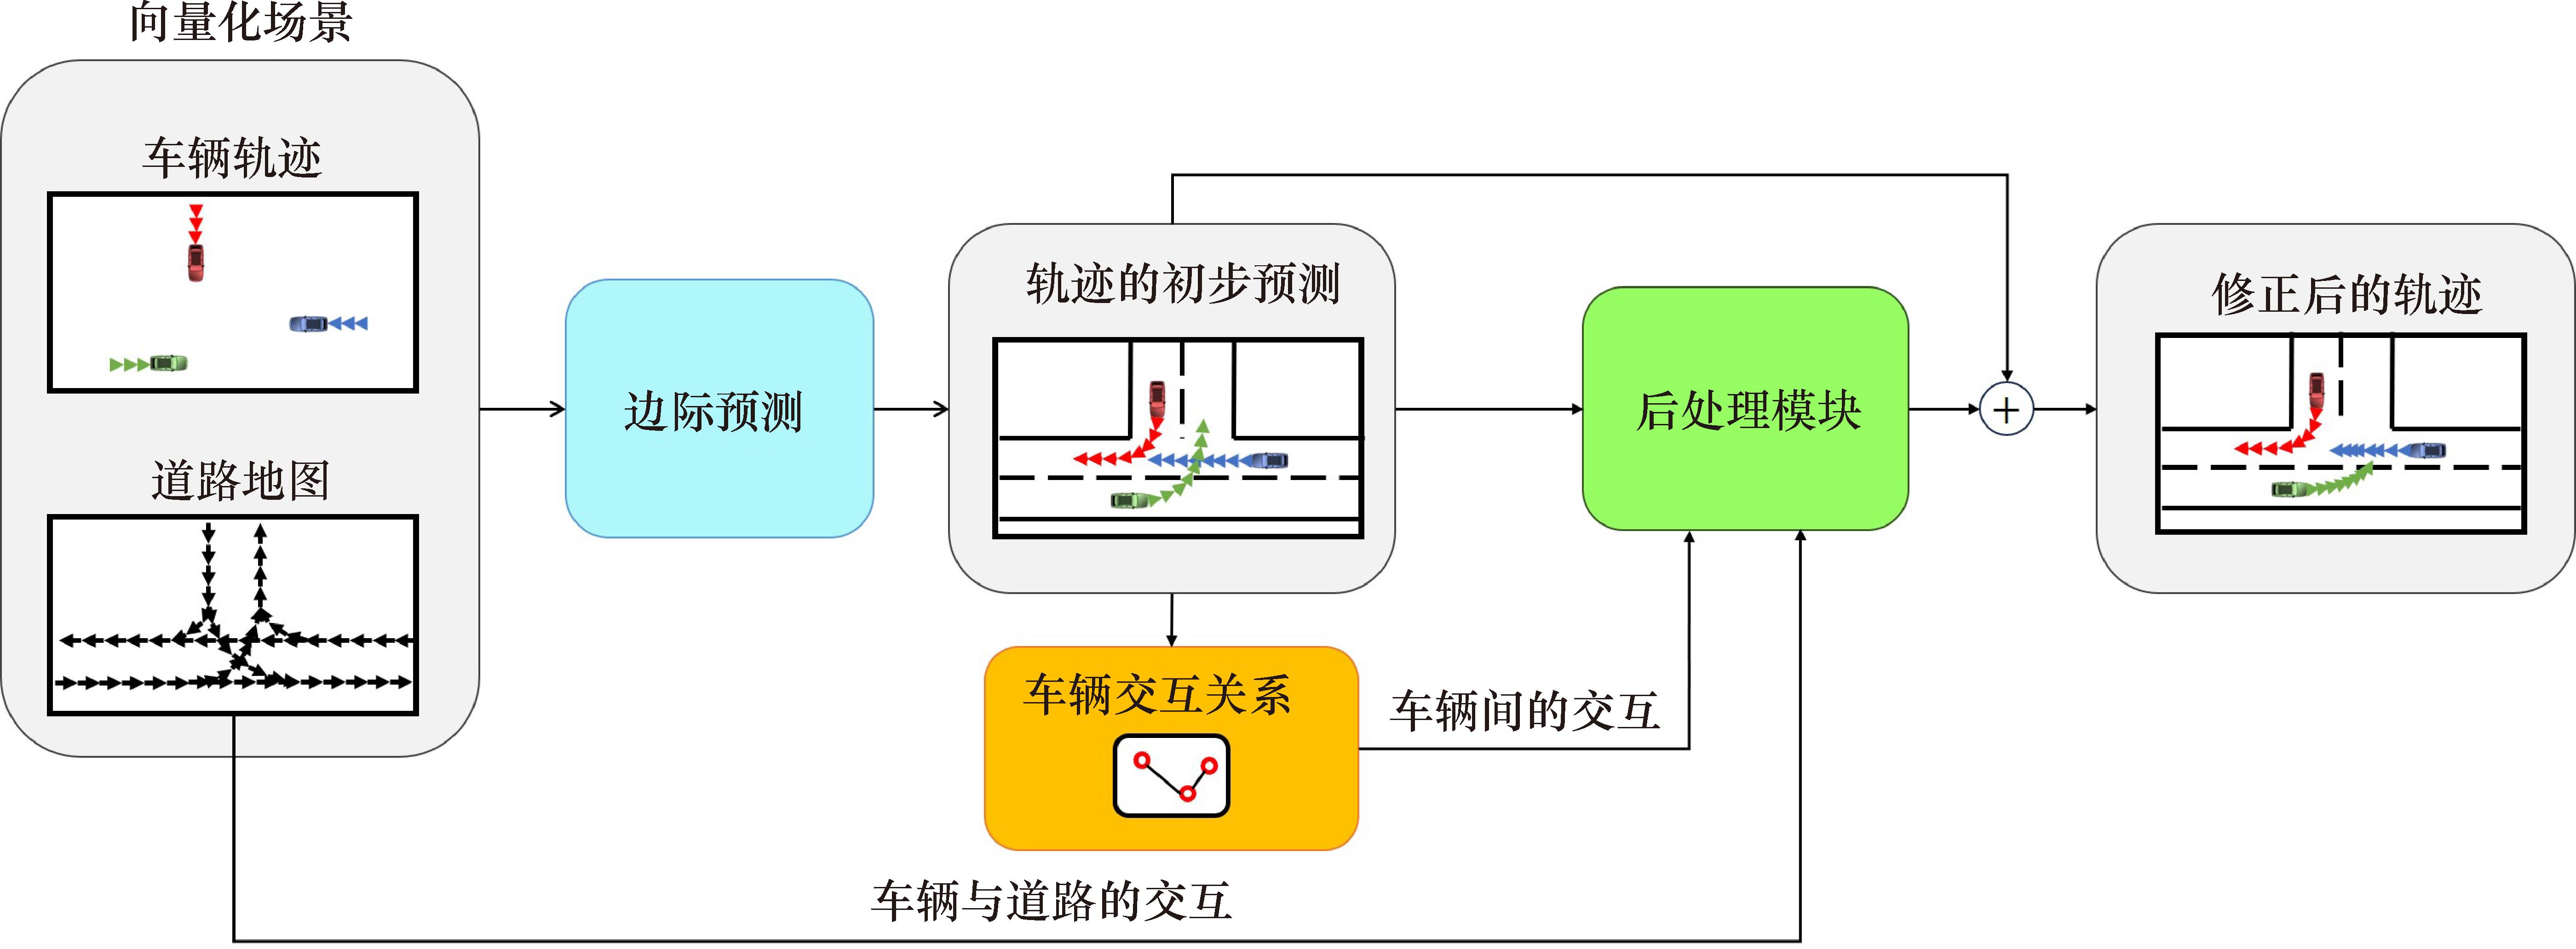
图2 TPP方法的整体结构
Fig.2 Framework of the TPP method
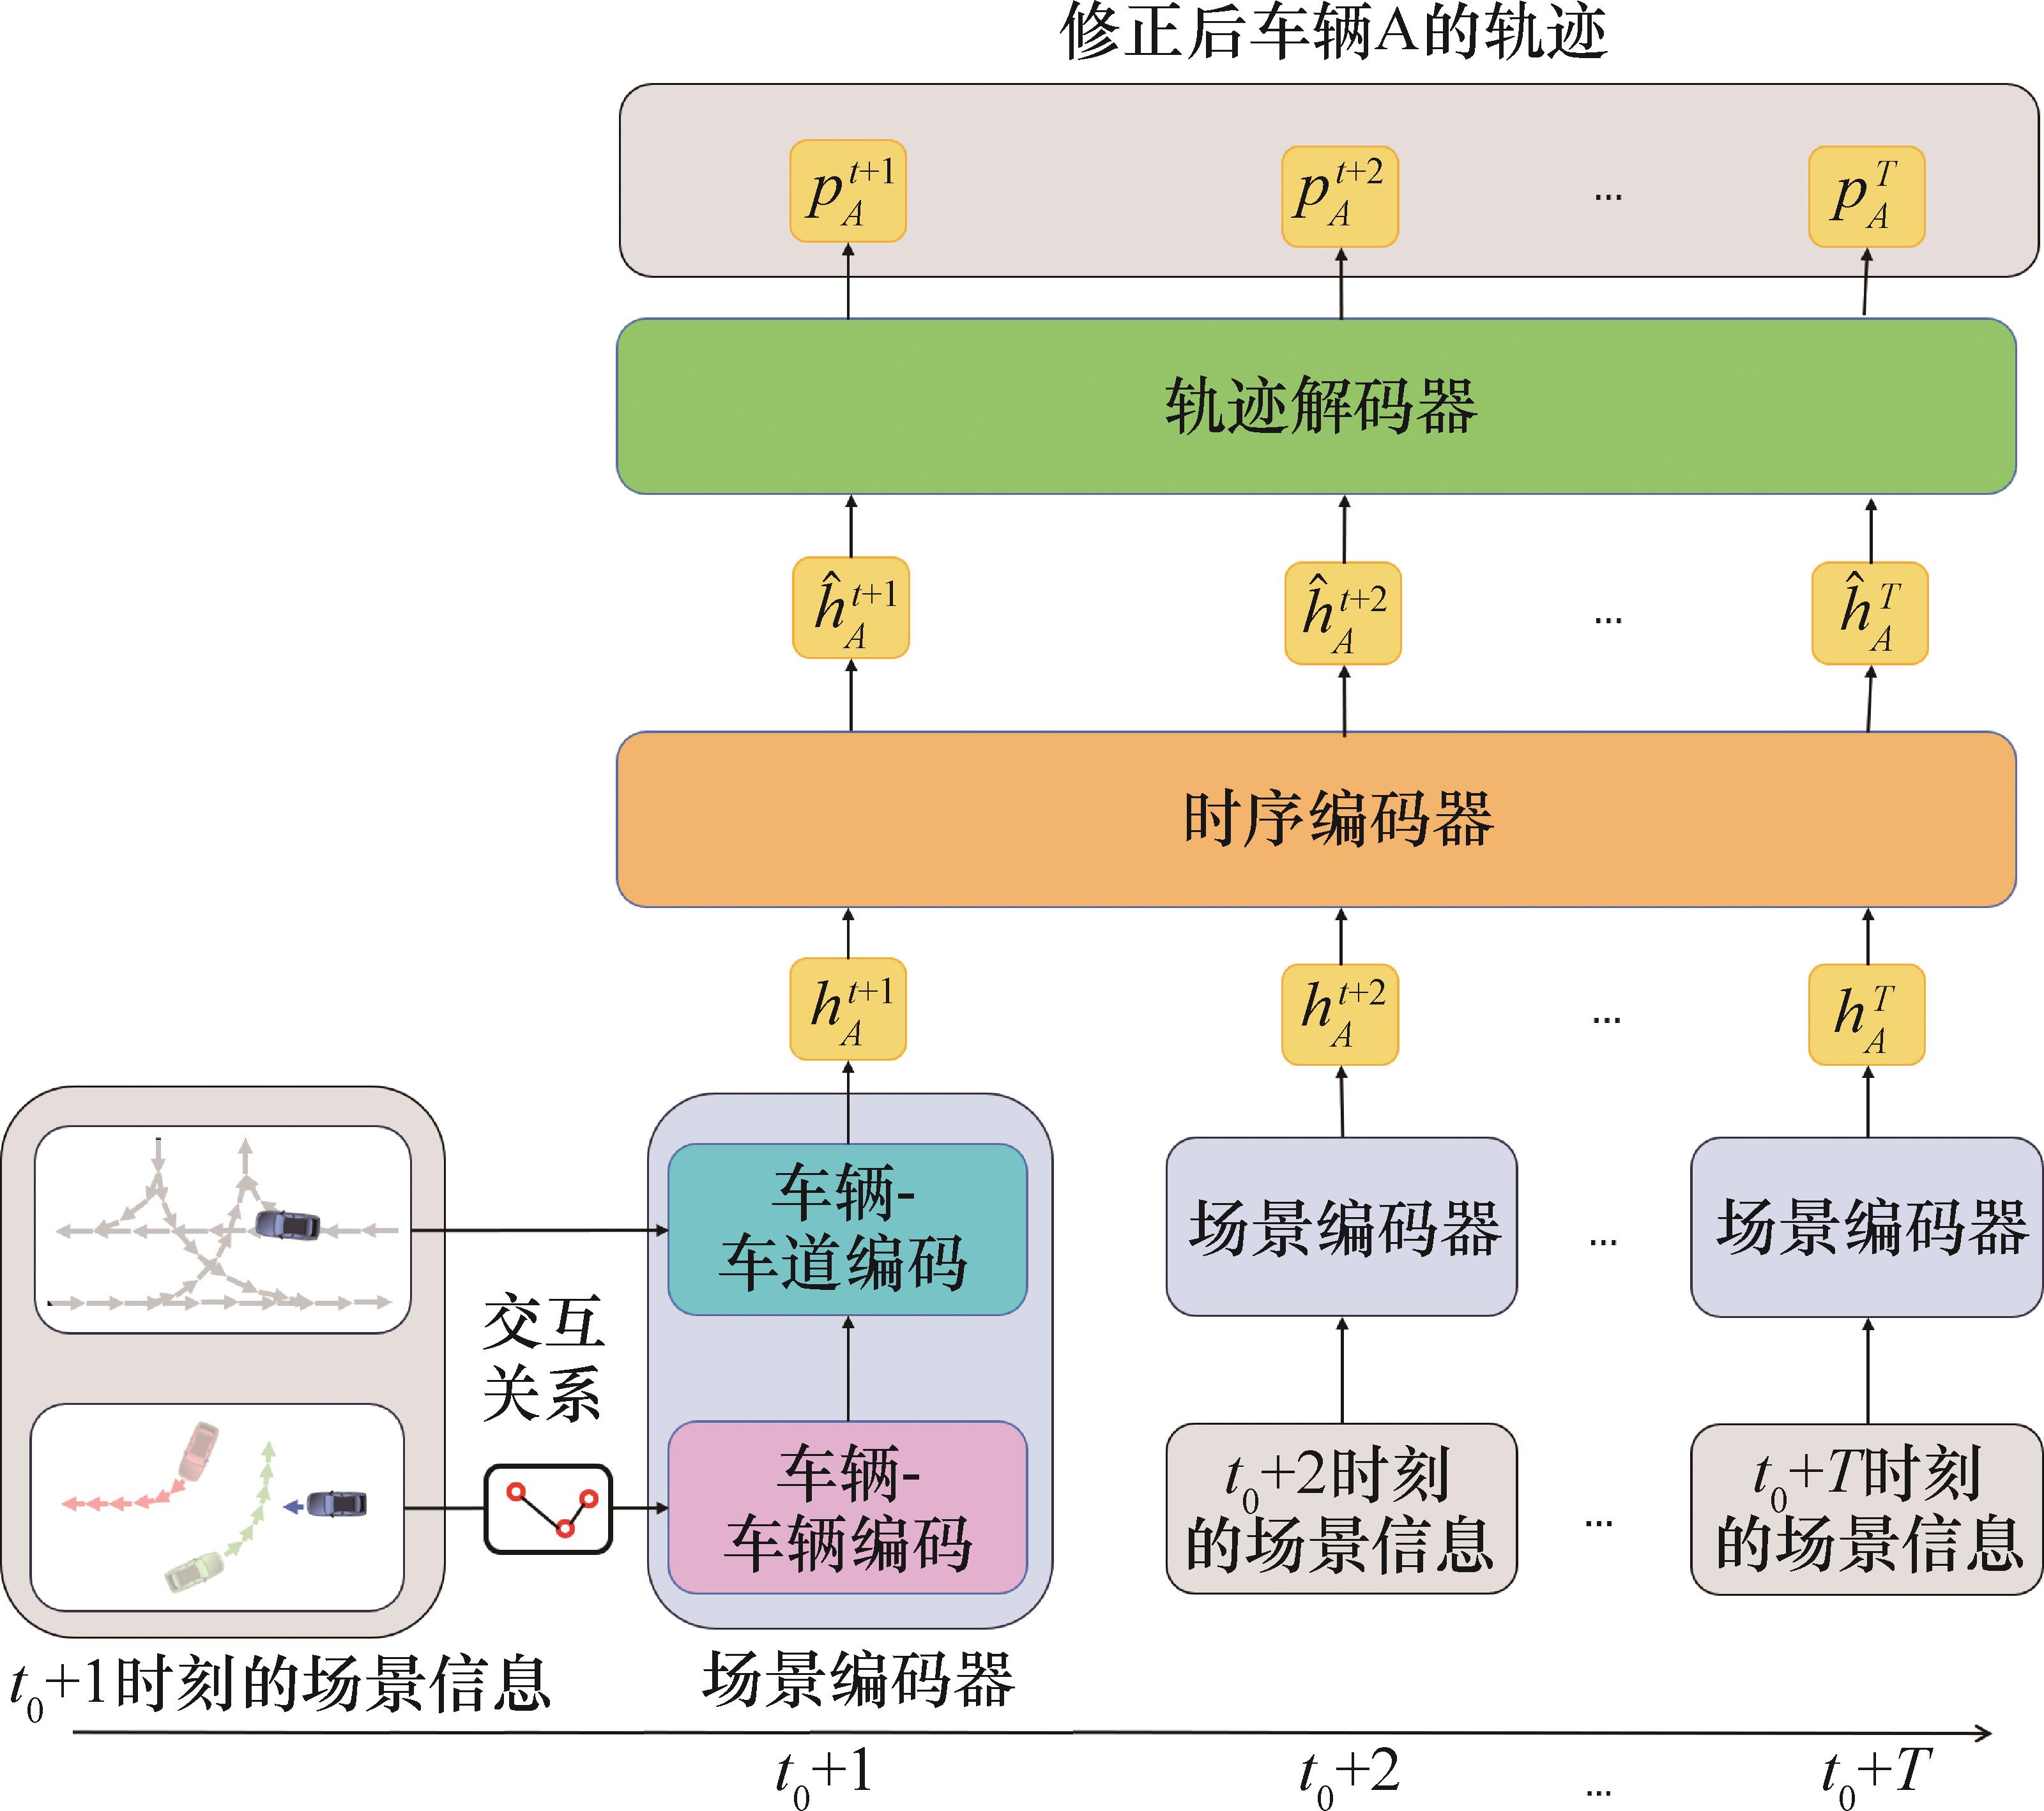
图3 轨迹后处理模块
Fig.3 Structure of trajectory post-processing module
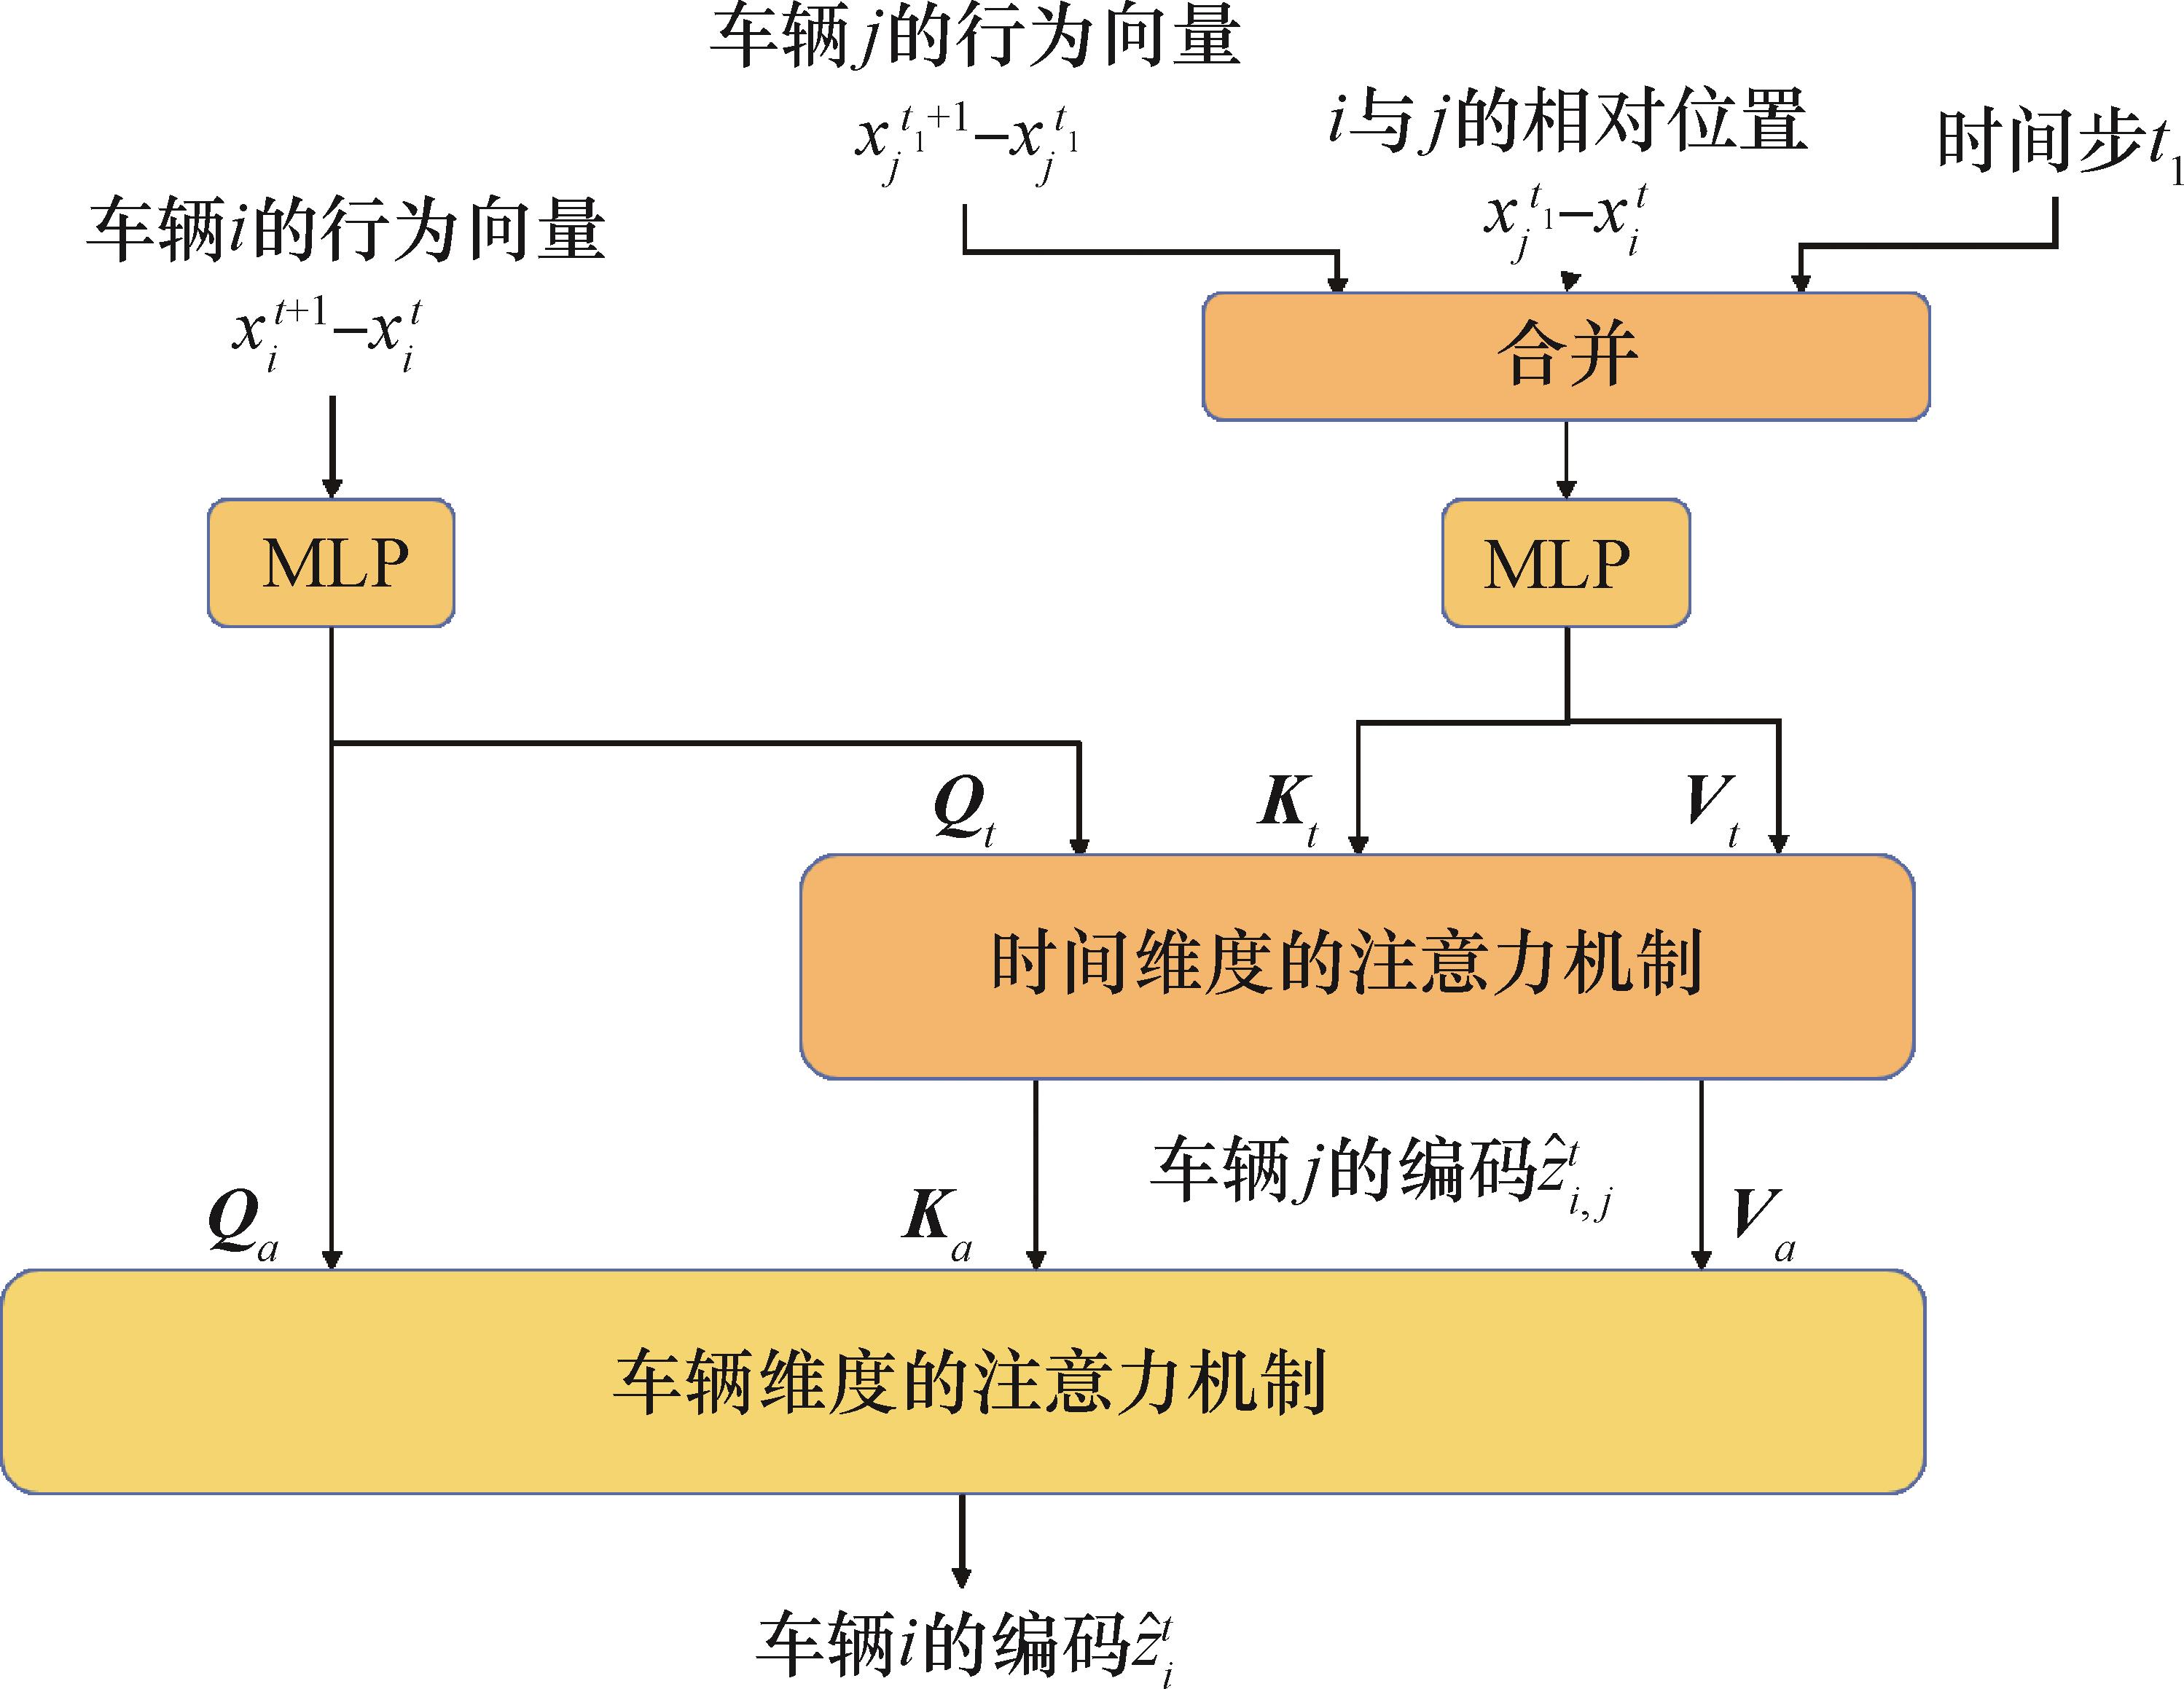
图4 车辆-车辆编码中使用的双层注意力机制
Fig.4 Dual-layer attention mechanism used in vehicle-vehicle encoder

图5 北京交通发展研究院的TrafficHUT数据库
Fig.5 TrafficHUT dataset from Beijing Transport Institute
| minADE↓/m | minFDE↓/m | MR↓ | |
|---|---|---|---|
| 基于图的方法[ | 0.87 | 1.36 | 0.16 |
| 目标导向的方法[ | 0.76 | 1.04 | 0.10 |
| HiVT[ | 0.69 | 1.05 | 0.10 |
| TPP | 0.69 | 1.02 | 0.10 |
表1 在Argoverse数据集上结果的定量对比
Table 1 Quantitative comparison on Argoverse dataset
| minADE↓/m | minFDE↓/m | MR↓ | |
|---|---|---|---|
| 基于图的方法[ | 0.87 | 1.36 | 0.16 |
| 目标导向的方法[ | 0.76 | 1.04 | 0.10 |
| HiVT[ | 0.69 | 1.05 | 0.10 |
| TPP | 0.69 | 1.02 | 0.10 |
| minADE↓/m | minFDE↓/m | MR↓ | CR↓ | |
|---|---|---|---|---|
| HiVT[ | 3.82 | 7.33 | 0.486 0 | 0.145 2 |
| TPP | 1.96 | 3.57 | 0.339 5 | 0.091 5 |
表2 在TrafficHUT数据集上结果的定量对比
Table 2 Quantitative comparison on TrafficHUT dataset
| minADE↓/m | minFDE↓/m | MR↓ | CR↓ | |
|---|---|---|---|---|
| HiVT[ | 3.82 | 7.33 | 0.486 0 | 0.145 2 |
| TPP | 1.96 | 3.57 | 0.339 5 | 0.091 5 |
| 车辆-车辆编码 | 车辆-车道编码 | 残差连接 | Temporal1 | Temporal2 | minADE/m | minFDE/m | MR | CR |
|---|---|---|---|---|---|---|---|---|
| — | √ | √ | √ | — | 2.01 | 3.76 | 0.357 0 | 0.098 7 |
| √ | — | √ | √ | — | 1.98 | 3.61 | 0.343 0 | 0.093 2 |
| √ | √ | — | √ | — | 2.11 | 4.13 | 0.365 0 | 0.117 6 |
| √ | √ | √ | — | √ | 2.08 | 4.23 | 0.362 0 | 0.128 5 |
| √ | √ | √ | √ | — | 1.96 | 3.57 | 0.339 5 | 0.091 5 |
表3 对网络中不同模块的消融实验
Table 3 Ablation study on different components
| 车辆-车辆编码 | 车辆-车道编码 | 残差连接 | Temporal1 | Temporal2 | minADE/m | minFDE/m | MR | CR |
|---|---|---|---|---|---|---|---|---|
| — | √ | √ | √ | — | 2.01 | 3.76 | 0.357 0 | 0.098 7 |
| √ | — | √ | √ | — | 1.98 | 3.61 | 0.343 0 | 0.093 2 |
| √ | √ | — | √ | — | 2.11 | 4.13 | 0.365 0 | 0.117 6 |
| √ | √ | √ | — | √ | 2.08 | 4.23 | 0.362 0 | 0.128 5 |
| √ | √ | √ | √ | — | 1.96 | 3.57 | 0.339 5 | 0.091 5 |
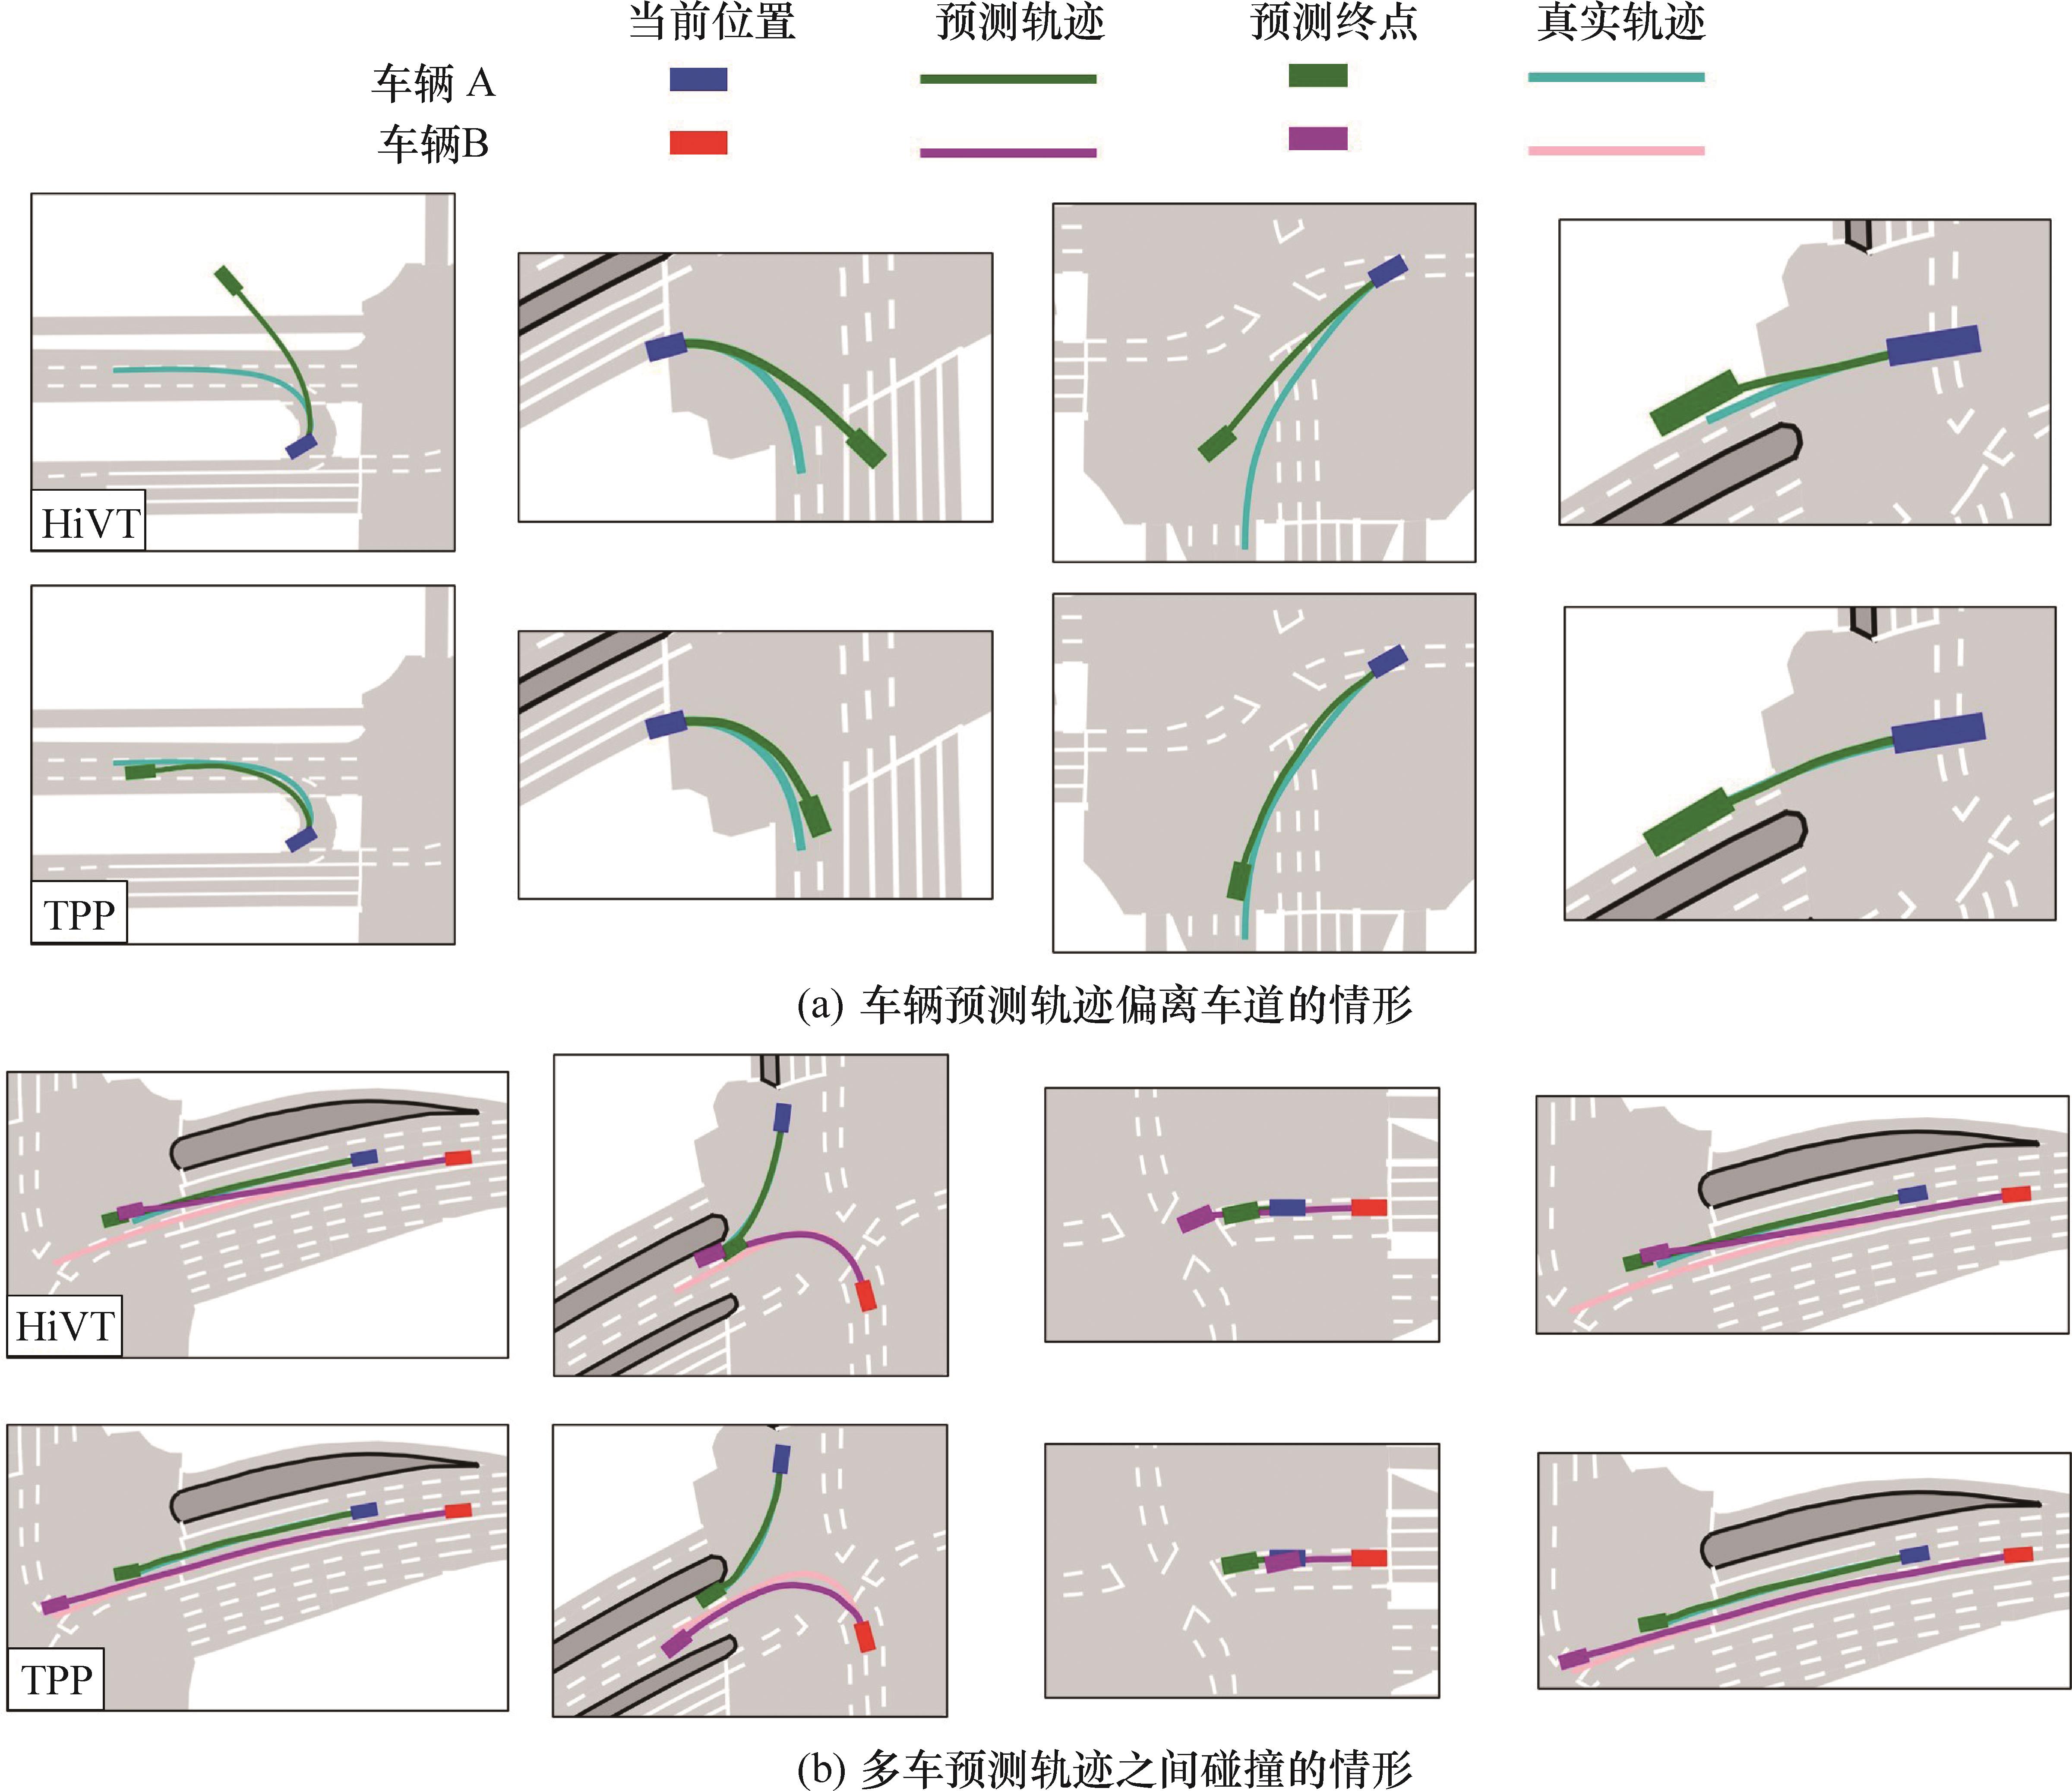
图6 TPP方法与基线算法的可视化对比
Fig.6 Visual comparison between our TPP method and baseline model
| [1] | 徐杰,裴晓飞,杨波,等. 融合车辆轨迹预测的学习型自动驾驶决策[J].汽车安全与节能学报, 2022,13(2):317-324.DOI:10.3969/j.issn.1674-8484.2022.02.012 . |
| [2] | 王卫锋, 胡靖昊, 贺琰, 等. 出租车司机的多源轨迹同轨分析[J]. 中国科学院大学学报, 2023, 40(3): 313-321. DOI: 10.7523/j.ucas.2021.0078 . |
| [3] | Salzmann T, Ivanovic B, Chakravarty P, et al. Trajectron++: dynamically-feasible trajectory forecasting with heterogeneous data[C]//European Conference on Computer Vision. Glasgow: Springer, 2020: 683-700. DOI: 10.1007/978-3-030-58523-5_40 . |
| [4] | Gilles T, Sabatini S, Tsishkou D, et al. HOME: heatmap output for future motion estimation[C]//2021 IEEE International Intelligent Transportation Systems Conference (ITSC). Indianapolis, IN, USA. IEEE, 2021: 500-507. DOI: 10.1109/ITSC48978.2021.9564944 . |
| [5] | Liang M, Yang B, Hu R, et al. Learning lane graph representations for motion forecasting[C]//European Conference on Computer Vision. Glasgow: 2020: 541-556. DOI: 10.1007/978-3-030-58536-5_32 . |
| [6] | Zhou Z K, Ye L Y, Wang J P, et al. HiVT: hierarchical vector transformer for multi-agent motion prediction[C]//2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). New Orleans, LA, USA. IEEE, 2022: 8813-8823. DOI: 10.1109/CVPR52688.2022.00862 . |
| [7] | Zhao H, Gao J Y, Lan T, et al. TNT: target-driveN trajectory prediction[C/OL]//Conference on Robot Learning. PMLR, 2021: 895-904. . |
| [8] | Gu J R, Sun C, Zhao H. DenseTNT: end-to-end trajectory prediction from dense goal sets[C]// 2021 IEEE/CVF International Conference on Computer Vision (ICCV). Montreal, QC, Canada. IEEE, 2021: 15283-15292. DOI: 10.1109/ICCV48922.2021.01502 . |
| [9] | Gilles T, Sabatini S, Tsishkou D, et al. GOHOME: graph-oriented heatmap output for future motion estimation[C]//2022 International Conference on Robotics and Automation (ICRA).Philadelphia, PA, USA. IEEE, 2022: 9107-9114. DOI: 10.1109/ICRA46639.2022.9812253 |
| [10] | Gilles T, Sabatini S, Tsishkou D, et al. THOMAS: trajectory heatmap output with learned multi-agent sampling[EB/OL]. arXiv 2021: 2110.06607.(2021-10-13)[2024-01-14].. |
| [11] | Zhang Q C, Gao Y F, Zhang Y K, et al. TrajGen: generating realistic and diverse trajectories with reactive and feasible agent behaviors for autonomous driving[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(12): 24474-24487 . DOI: 10.1109/TITS.2022.3202185 |
| [12] | Zeng W Y, Liang M, Liao R J, et al. LaneRCNN: distributed representations for graph-centric motion forecasting[C]//2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Prague, Czech Republic. IEEE, 2021: 532-539. DOI: 10.1109/IROS51168.2021.9636035 . |
| [13] | Varadarajan B, Hefny A, Srivastava A, et al. MultiPath++: efficient information fusion and trajectory aggregation for behavior prediction[C]//2022 International Conference on Robotics and Automation (ICRA). ACM, 2022: 7814-7821. DOI: 10.1109/ICRA46639.2022.9812107 . |
| [14] | Sun Q, Huang X, Gu J R, et al. M2I: from factored marginal trajectory prediction to interactive prediction[C]//2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). New Orleans, LA, USA. IEEE, 2022: 6533-6542. DOI: 10.1109/CVPR52688.2022.00643 . |
| [15] | Rowe L, Ethier M, Dykhne E H, et al. FJMP: factorized joint multi-agent motion prediction over learned directed acyclic interaction graphs[C]//2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Vancouver, BC, Canada. IEEE, 2023: 13745-13755. DOI: 10.1109/CVPR52729.2023.01321 . |
| [16] | Li D, Zhang Q C, Lu S, et al. Conditional goal-oriented trajectory prediction for interacting vehicles[J]. IEEE Transactions on Neural Networks and Learning Systems, 2023, 35(12): 18758-18770. DOI: 10.1109/TNNLS.2023.3321564 . |
| [17] | Jiang C, Cornman A, Park C, et al. MotionDiffuser: controllable multi-agent motion prediction using diffusion[C]//2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Vancouver, BC, Canada. IEEE, 2023: 9644-9653. DOI: 10.1109/CVPR52729.2023.00930 . |
| [18] | Phan-Minh T, Grigore E C, Boulton F A, et al. Covernet: multimodal behavior prediction using trajectory sets[C]// 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Seattle, WA, USA. IEEE, 2020: 14062-14071. DOI: 10.1109/CVPR42600.2020.01408 . |
| [19] | Chen Y X, Ivanovic B, Pavone M. scePT: scene-consistent, policy-based trajectory predictions for planning[C]// 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). New Orleans, LA, USA. IEEE, 2022: 17082-17091. DOI: 10.1109/CVPR52688.2022.01659 . |
| [20] | Bi H K, Mao T L, Wang Z Q, et al. A deep learning-based framework for intersectional traffic simulation and editing[J]. IEEE Transactions on Visualization and Computer Graphics, 2020, 26(7): 2335-2348. DOI: 10.1109/TVCG.2018.2889834 . |
| [21] | Chai Y N, Sapp B, Bansal M, et al. MultiPath: multiple probabilistic anchor trajectory hypotheses for behavior prediction[EB/OL]. arXiv 2019: 1910.05449.(2019-10-12)[2024-01-14].. |
| [22] | Gao J Y, Sun C, Zhao H, et al. VectorNet: encoding HD maps and agent dynamics from vectorized representation[C]// 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Seattle, WA, USA. IEEE, 2020: 11522-11530. DOI: 10.1109/CVPR42600.2020.01154 . |
| [23] | Luo W J, Park C, Cornman A, et al. JFP: joint future prediction with interactive multi-agent modeling for autonomous driving[C]//Conference on Robot Learning. PMLR, 2023: 1457-1467. DOI: 10.48550/arxiv.2212.08710 . |
| [24] | Cheng H, Liu M M, Chen L, et al. GATraj: a graph-and attention-based multi-agent trajectory prediction model[J]. ISPRS Journal of Photogrammetry and Remote Sensing, 2023, 205: 163-175. DOI: 10.1016/j.isprsjprs.2023.10.001 |
| [25] | 连静,丁荣琪,李琳辉,等.基于图模型和注意力机制的车辆轨迹预测方法[J].兵工学报, 2023, 44(7): 2162-2170. DOI: 10.12382/bgxb.2022.0117 . |
| [26] | Yuan Y, Weng X S, Ou Y L, et al. AgentFormer: agent-aware transformers for socio-temporal multi-agent forecasting[C]// 2021 IEEE/CVF International Conference on Computer Vision (ICCV). Montreal, QC, Canada. IEEE, 2021: 9793-9803. DOI: 10.1109/ICCV48922.2021.00967 . |
| [27] | Ngiam J, Caine B, Vasudevan V, et al. Scene transformer: a unified architecture for predicting multiple agent trajectories[EB/OL]. arXiv 2021: 2106.08417.(2021-06-15)[2024-01-14].. |
| [28] | Liu Y C, Zhang J H, Fang L J, et al. Multimodal motion prediction with stacked transformers[C]// 2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Nashville, TN, USA. IEEE, 2021: 7573-7582. DOI: 10.1109/CVPR46437.2021.00749 |
| [29] | Huang Z Y, Liu H C, Lv C. GameFormer: game-theoretic modeling and learning of transformer-based interactive prediction and planning for autonomous driving[C]//2023 IEEE/CVF International Conference on Computer Vision (ICCV). Paris, France. IEEE, 2023: 3880-3890. DOI: 10.1109/ICCV51070.2023.00361 . |
| [30] | Shi S S, Jiang L, Dai D X, et al. MTR++: multi-agent motion prediction with symmetric scene modeling and guided intention querying[J]. IEEE Trans Pattern Anal Mach Intell, 2024, 46(5): 3955-3971. DOI: 10.1109/tpami.2024.3352811 . |
| [31] | 李文礼,韩迪,石晓辉,等.基于时-空注意力机制的车辆轨迹预测[J].中国公路学报, 2023, 36(1):226-239.DOI:10.19721/j.cnki.1001-7372.2023.01.018 . |
| [32] | Pang Y T, Guo Z H, Zhuang B N. ProspectNet: weighted conditional attention for future interaction modeling in behavior prediction[EB/OL]. arXiv 2022: 2208.13848.(2022-08-29)[2024-01-14]. . |
| [33] | 秦胜君,李婷.多交互车辆轨迹预测研究[J].计算机工程与应用, 2021, 57(11): 232-238.DOI:10.3778/j.issn.1002-8331.2005-0154 . |
| [34] | 连静,李硕贤,刘一荻,等.基于车道目标引导的车辆轨迹预测[J].汽车工程, 2023, 45(8):1353-1361.DOI: 10.19562/j.chinasae.qcgc.2023.08.006 |
| [35] | Tang Y C, Salakhutdinov R. Multiple futures prediction[EB/OL]. arXiv 2019: 1911.00997.(2019-11-04)[2024-01-14]. . |
| [36] | Seff A, Cera B, Chen D, et al. MotionLM: multi-agent motion forecasting as language modeling[C]//2023 IEEE/CVF International Conference on Computer Vision (ICCV). Paris, France. IEEE, 2023: 8545-8556. DOI: 10.1109/ICCV51070.2023.00788 . |
| [37] | 季学武, 费聪, 何祥坤, 等. 基于LSTM网络的驾驶意图识别及车辆轨迹预测[J]. 中国公路学报, 2019, 32(6): 34-42. DOI: 10.19721/j.cnki.1001-7372.2019.06.003 . |
| [38] | 吴晓建,危一华,王爱春,等.基于融合Dropout与注意力机制的LSTM-GRU车辆轨迹预测[J].湖南大学学报(自然科学版), 2023, 50(4):65-75.DOI: 10.16339/j.cnki.hdxbzkb.2023155 |
| [39] | 张晓宁.基于LSTM网络的车辆轨迹预测研究[J].汽车实用技术, 2020, 45(22): 32-33, 39.DOI:10.16638/j.cnki.1671-7988.2020.22.011 . |
| [40] | Niedoba M, Lavington J, Liu Y P, et al. A diffusion-model of joint interactive navigation [EB/OL]. arXiv 2023: 2309.12508.(2023-09-21)[2024-01-14].. |
| [41] | Chang W J, Tang C, Li C R, et al. Editing driver character: socially-controllable behavior generation for interactive traffic simulation[J]. IEEE Robotics and Automation Letters, 2023, 8(9): 5432-5439. DOI: 10.1109/LRA.2023.3291897 . |
| [42] | Tai Y, Yang J, Liu X M, et al. Memnet: a persistent memory network for image restoration[C]// 2017 IEEE International Conference on Computer Vision (ICCV). Venice, Italy. IEEE, 2017: 4549-4557. DOI: 10.1109/ICCV.2017.486 . |
| [43] | Devlin J, Chang M W, Lee K, et al. BERT: pre-training of deep bidirectional transformers for language understanding[EB/OL]. arXiv 2018: 1810.04805.(2018-10-11)[2024-01-14].. |
| [44] | Chang M F, Lambert J, Sangkloy P, et al. Argoverse: 3D tracking and forecasting with rich maps[C]//2019 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Long Beach, CA, USA. IEEE, 2019: 8740-8749. DOI: 10.1109/CVPR.2019.00895 . |
| [45] | 北京市交通发展研究院. TrafficHUT交通轨迹库[EB/OL]. (2023) [2024-01-14].. |
| [1] | 冯卓航, 申立勇. 基于CSG的二维CAD形状智能解析方法[J]. 中国科学院大学学报, 2026, 43(5): 603-613. |
| [2] | 肖远明, 贺连星. 基于深度学习的低副瓣稀疏阵列天线设计[J]. 中国科学院大学学报, 2026, 43(5): 650-656. |
| [3] | 毛紫茜, 张三国. 基于伽马散度的半监督自训练图像分类[J]. 中国科学院大学学报, 2026, 43(4): 433-443. |
| [4] | 姜翠, 焦建彬. 融合知识先验的车辆轨迹预测深度学习算法[J]. 中国科学院大学学报, 2026, 43(2): 209-217. |
| [5] | 孙瑞奇, 张文娟, 李震, 马雪松, 梅君林. 分块尺寸对大场景遥感图像空间超分应用的影响分析[J]. 中国科学院大学学报, 2026, 43(1): 93-103. |
| [6] | 周庆泽, 郭擎. 多重残差网络的多光谱遥感图像锐化方法[J]. 中国科学院大学学报, 2025, 42(4): 565-575. |
| [7] | 曾建顺, 吕炎杰, 覃驭楚. 基于多尺度语义先验的街景图像修复算法[J]. 中国科学院大学学报, 2025, 42(4): 496-507. |
| [8] | 钟金彦, 陈俊, 李宇, 吴业炜, 葛小青. 基于MFF-SFE的遥感图文跨模态检索方法[J]. 中国科学院大学学报, 2025, 42(2): 236-247. |
| [9] | 周文雪, 张华春. 一种面向SAR图像快速舰船检测的轻量化网络[J]. 中国科学院大学学报, 2024, 41(6): 776-785. |
| [10] | 喻永生, 罗铁坚. 基于GAN反演的无缝图像补全技术[J]. 中国科学院大学学报, 2024, 41(5): 705-714. |
| [11] | 陈经纬, 李宇, 陈俊, 张洪群. 基于MFF-Deeplabv3+网络的高分辨率遥感影像建筑物提取方法[J]. 中国科学院大学学报, 2024, 41(5): 654-664. |
| [12] | 黄玉林, 梁磊, 李卫军, 习晓环. 基于多尺度特征和注意力机制的深度学习点云压缩[J]. 中国科学院大学学报, 2024, 41(5): 687-694. |
| [13] | 林昱彤, 王红, 柴团耀. 基于卷积神经网络多尺度特征的大豆基因组表型预测[J]. 中国科学院大学学报, 2024, 41(4): 468-476. |
| [14] | 王兆瑞, 岩延, 张宝贤. 基于时空依赖关系多智能体强化学习的多路口交通信号协同控制方法[J]. 中国科学院大学学报, 2024, 41(3): 398-410. |
| [15] | 李雪源, 韩丛英. Actor-critic框架下的二次指派问题求解方法[J]. 中国科学院大学学报, 2024, 41(2): 275-284. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||